2025
Robust and Efficient 3D Gaussian Splatting for Urban Scene Reconstruction
IEEE/CVF International Conference on Computer Vision (ICCV), 2025
We are recruiting Ph.D. and master's students in Artificial Intelligence, Electronic Information, and Information and Communication Engineering. See admissions
Our directions build on one another: perceiving, reconstructing and understanding 3D environments, communicating reliably under constraints, and acting through vision and touch.
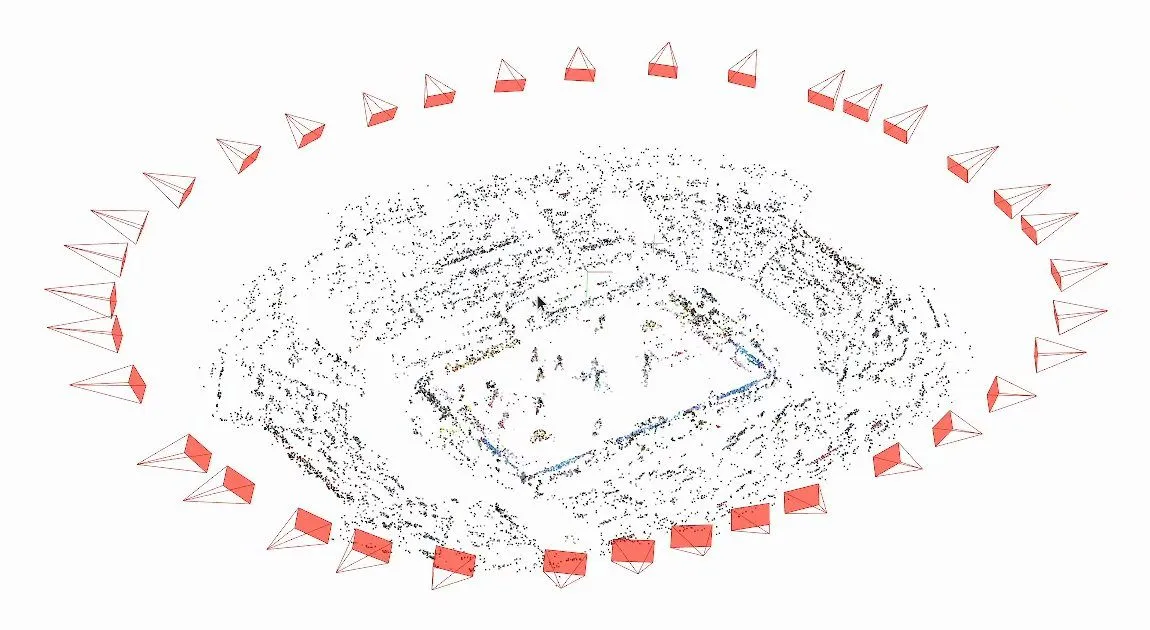
From point-cloud deep learning and self-supervised point-cloud understanding to city-scale 3D reconstruction, we turn images and point clouds into computable spatial structure. We also study video object tracking, person re-identification and perception for autonomous driving.
Research questionHow can city-scale 3D reconstruction maintain both rendering speed and robustness in complex scenes within the memory of consumer-grade GPUs?
Led by Guanghua Yang, with Di Wang and Haozhi Huang
IEEE/CVF International Conference on Computer Vision (ICCV), 2025
Pattern Recognition, 2022
IEEE Robotics and Automation Letters, 2022
IET Image Processing, 2021
We study URLLC, integrated sensing and communication (ISAC) and semantic communication for 6G, robust beamforming with reconfigurable antennas and intelligent surfaces, and airspace planning and vision-and-language navigation for low-altitude ISAC networks.
Research questionHow can distributed low-altitude ISAC networks stay reliable and robust under cross-layer non-ideal conditions?
Led by Zheng Shi, with Xu Wang and Jintao Wang
IEEE Transactions on Wireless Communications, 2024
IEEE Transactions on Wireless Communications, 2023
Journal of the Franklin Institute, 2023
IEEE International Symposium on Information Theory (ISIT), 2022
We study 6D object pose estimation, point-cloud processing, vision foundation models and SLAM so that robots can locate themselves and objects in real environments. On top of this we work on multimodal tactile sensing, high-resolution tactile reconstruction and touch-driven dexterous hand control.
Research questionHow can visual pose estimation and tactile feedback work together within a single manipulation task on real workpieces?
Led by Deping Li, with Xiaohua Wu
International Journal of Extreme Manufacturing (IJEM), 2026
Advanced Science, 2025
Our capture equipment covers aerial, ground and tabletop scales, plus a mmWave testbed for low-altitude sensing.
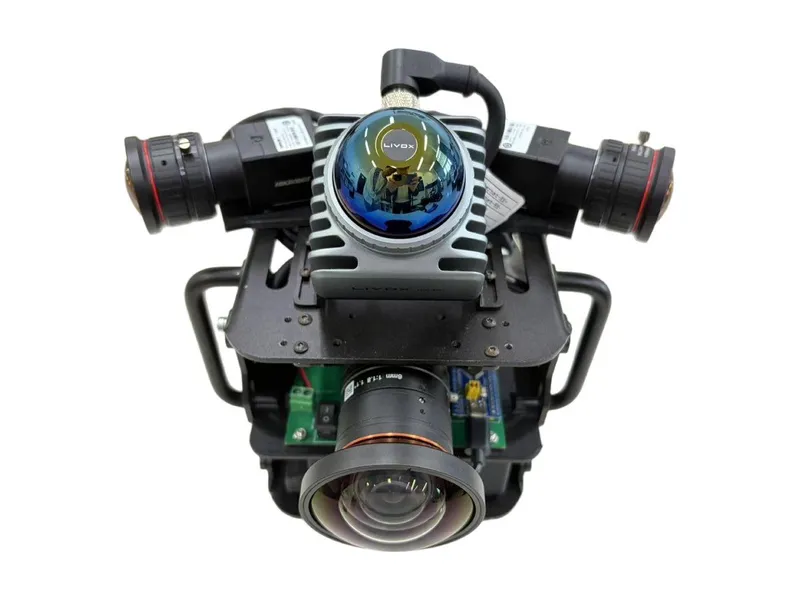
LiDAR, multi-camera array and IMU in one unit, used handheld or mounted on drones and robots.
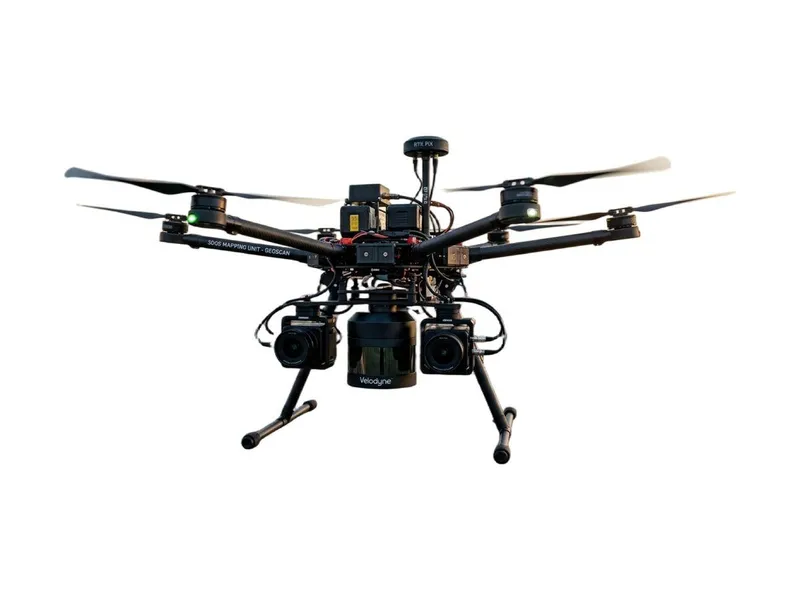
Carries cameras and LiDAR for aerial capture of campuses and other large sites.
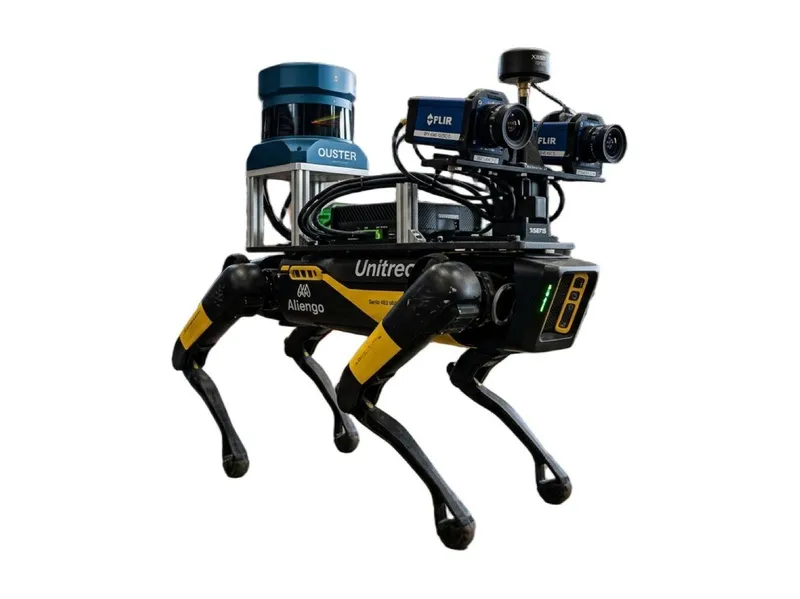
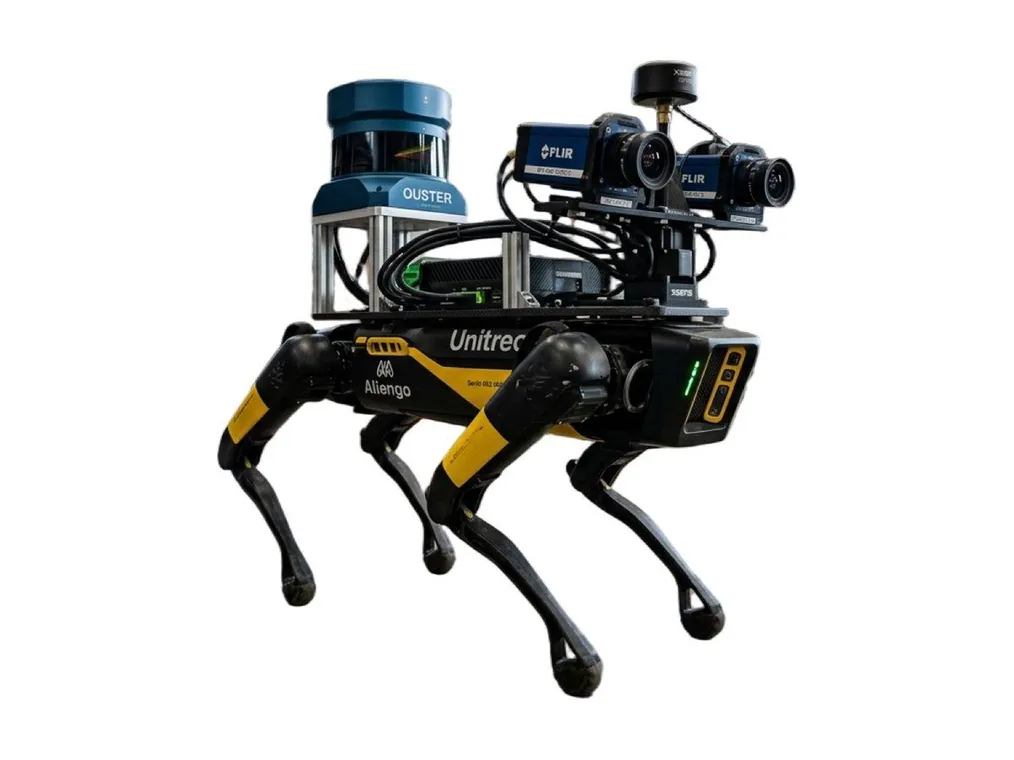
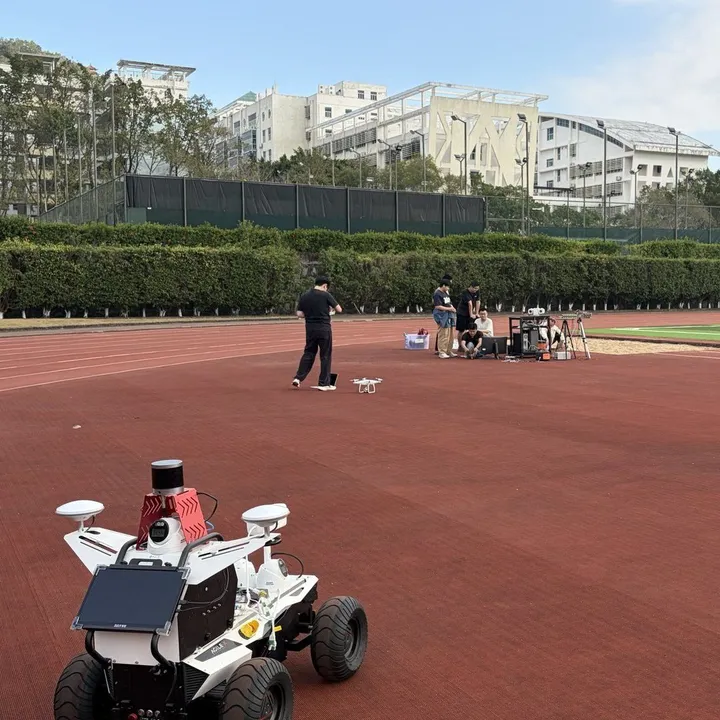
Carries LiDAR and cameras up stairs, through narrow passages and into indoor spaces, and is also used for SLAM experiments.
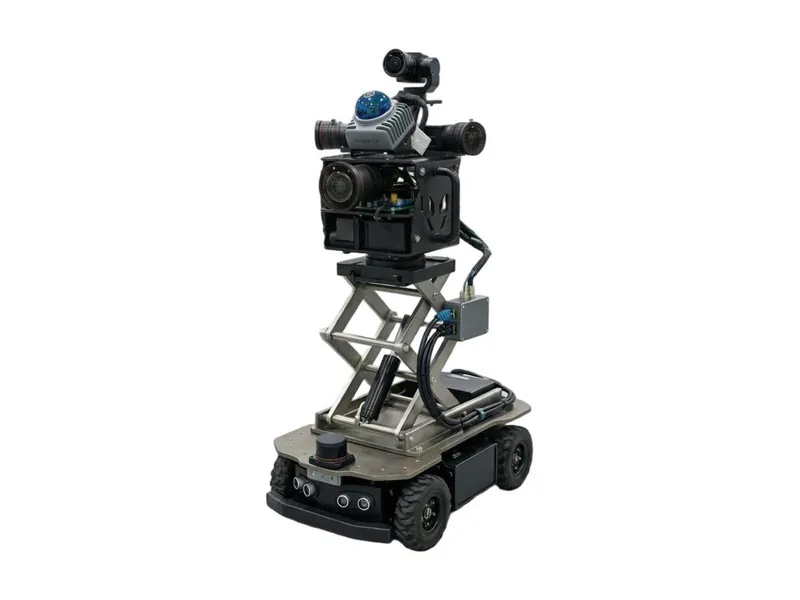
A lifting mast with multiple sensors for layered capture of facades and interiors.
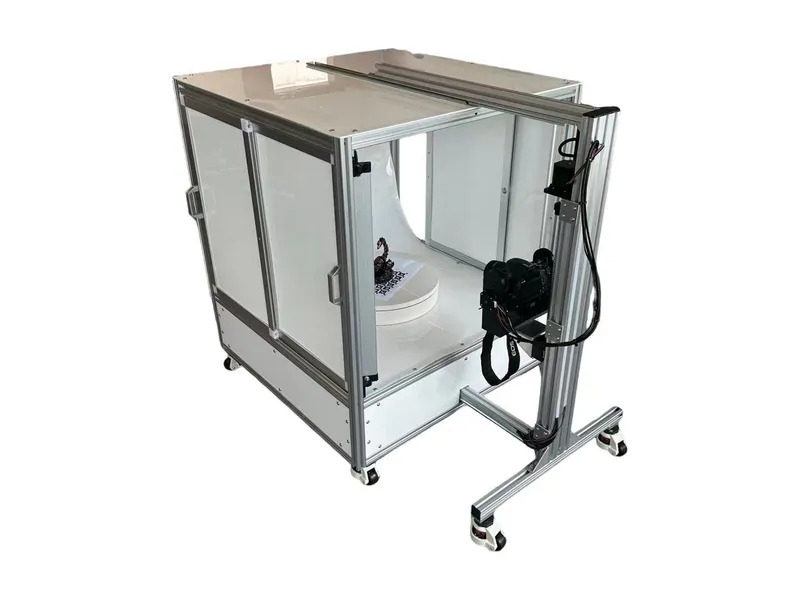
A camera, lighting and a turntable work together to capture 3D data of single objects.
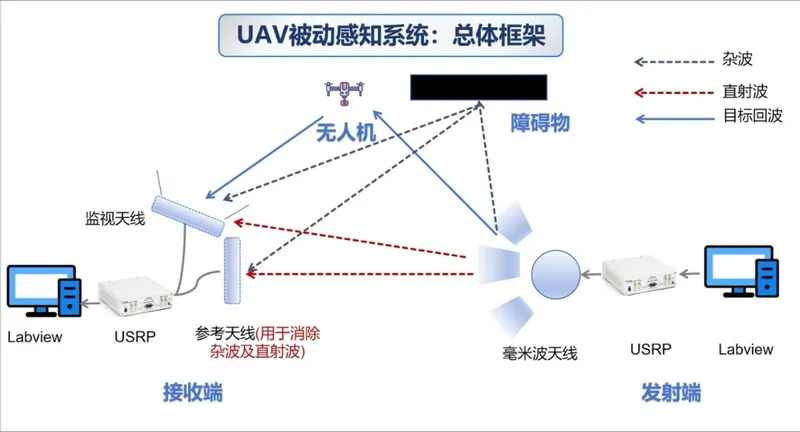
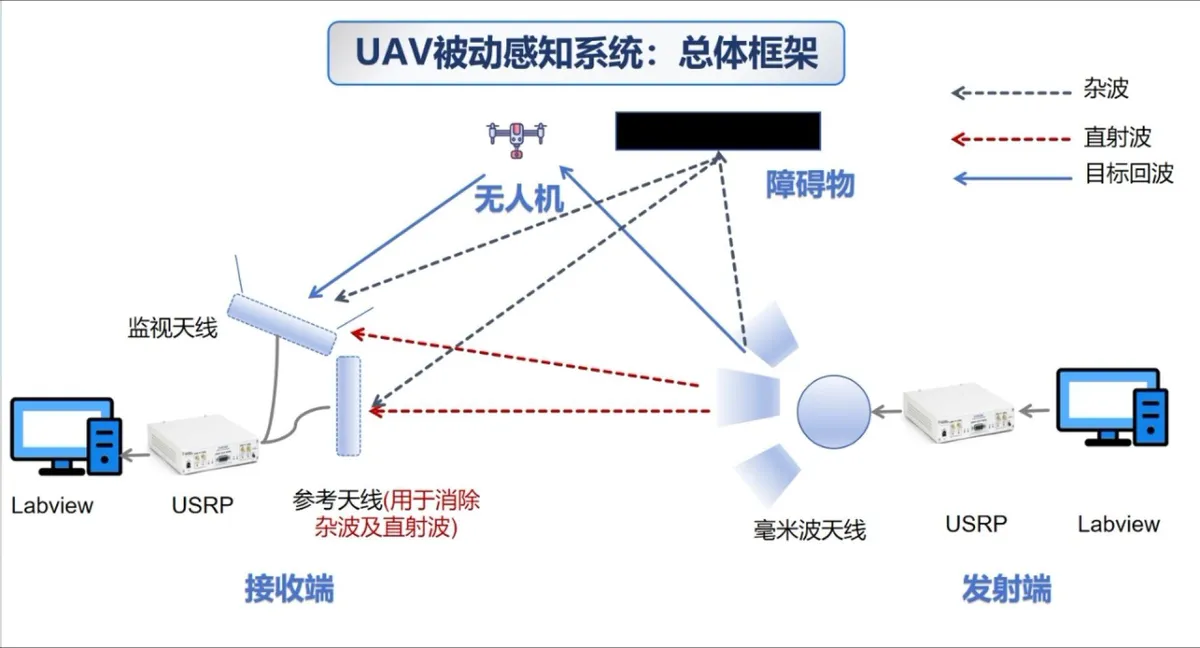
The transmitter uses a mmWave antenna and a USRP software-defined radio. The receiver uses surveillance and reference antennas with a second USRP. The system is used for UAV passive sensing experiments.
Whether you are applying for graduate study, joining undergraduate research or proposing a collaboration, tell us about your background, the direction you are interested in, and the question you want to work on.