2025
Robust and Efficient 3D Gaussian Splatting for Urban Scene Reconstruction
IEEE/CVF International Conference on Computer Vision (ICCV), 2025
实验室招收人工智能、电子信息、信息与通信工程方向博士与硕士研究生,并接收本科生参加科研训练。查看招生信息
三个方向前后衔接。研究从三维环境的感知、重建与理解出发,延伸至受限条件下的可靠通信,以及基于视觉与触觉的操作。
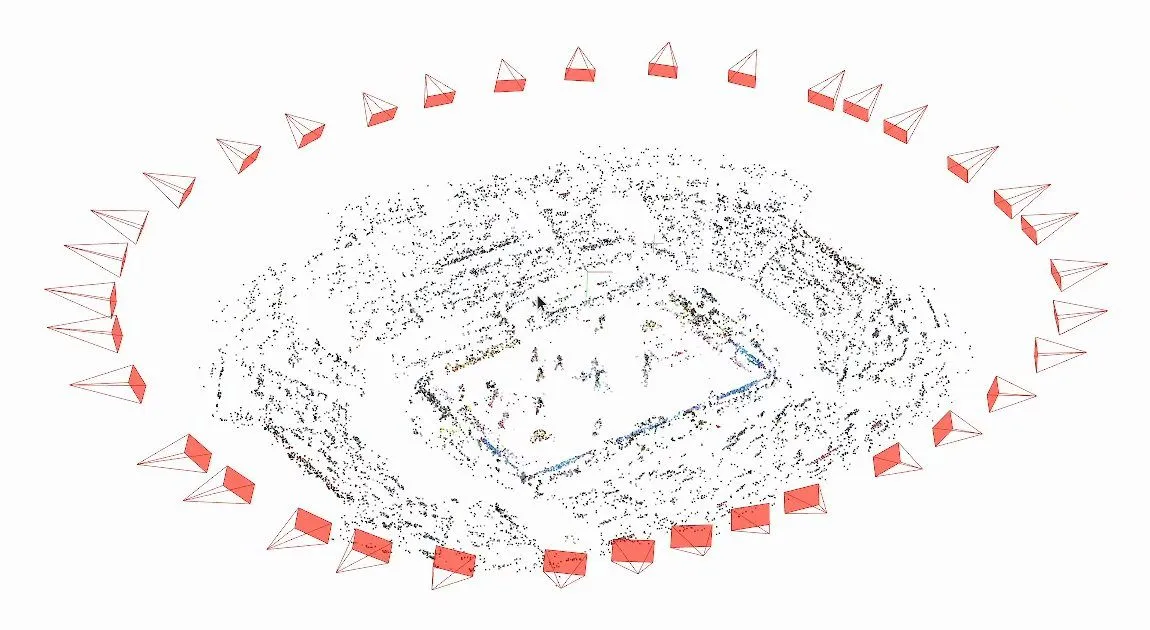
IEEE/CVF International Conference on Computer Vision (ICCV), 2025
Pattern Recognition, 2022
IEEE Robotics and Automation Letters, 2022
IET Image Processing, 2021
IEEE Transactions on Wireless Communications, 2024
IEEE Transactions on Wireless Communications, 2023
Journal of the Franklin Institute, 2023
IEEE International Symposium on Information Theory (ISIT), 2022
International Journal of Extreme Manufacturing (IJEM), 2026
Advanced Science, 2025
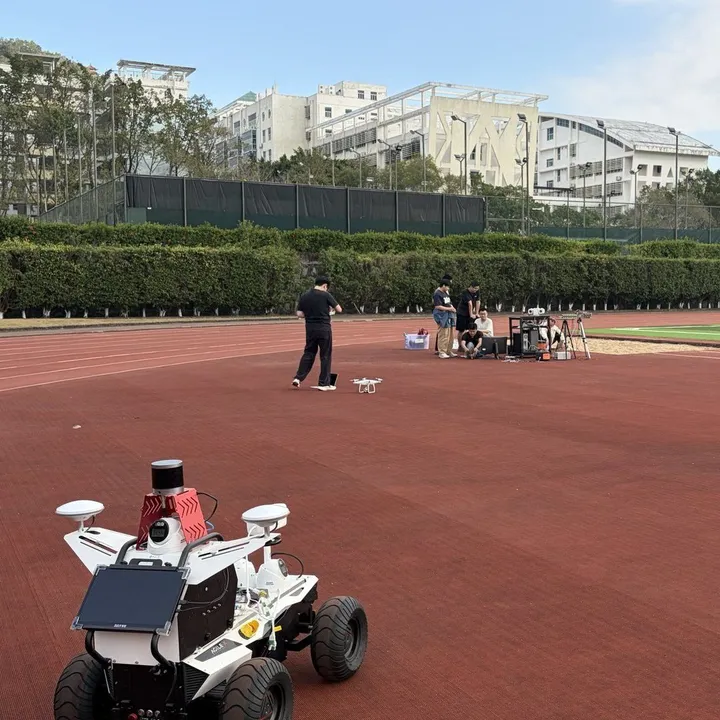
实验室的采集设备覆盖空中、地面与桌面三种尺度,另有用于低空感知验证的毫米波实验系统。
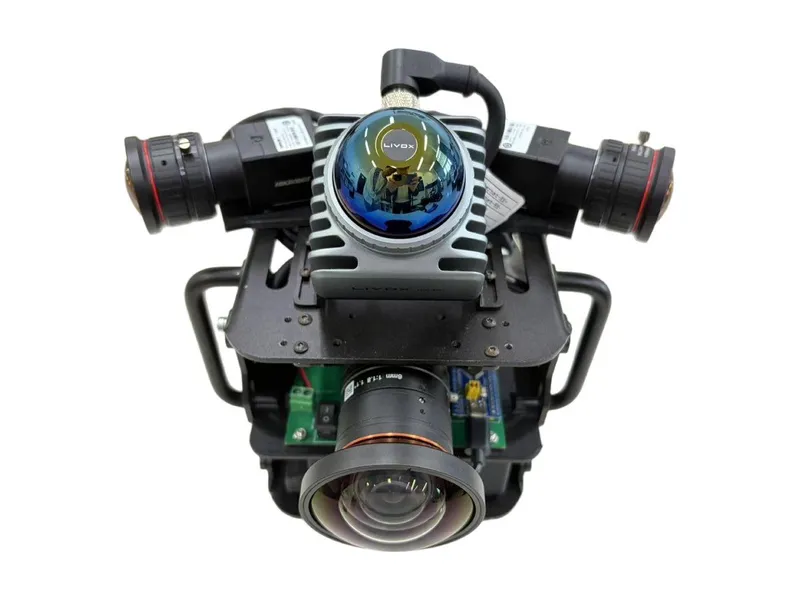
集成激光雷达、多目相机与惯性测量单元,可手持或搭载在无人机、机器人上采集。
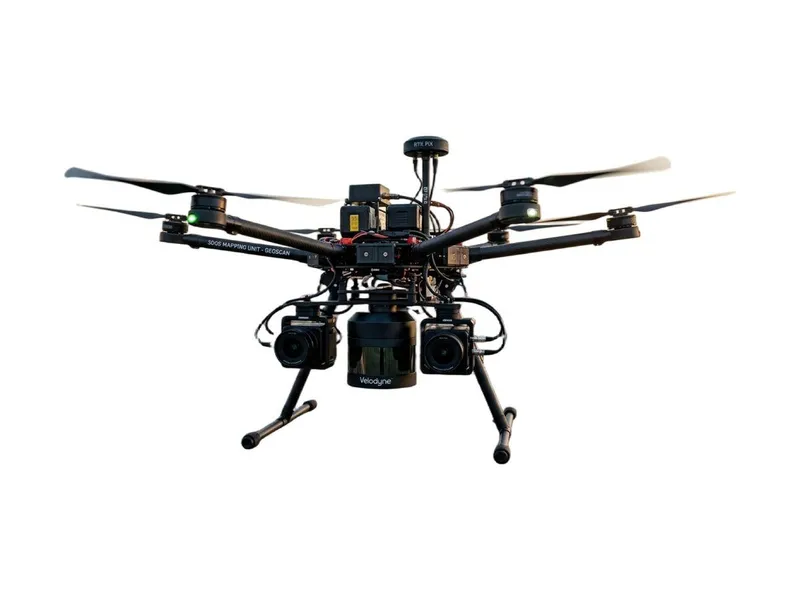
搭载相机与激光雷达,用于校园、园区等大范围场景的航拍采集。
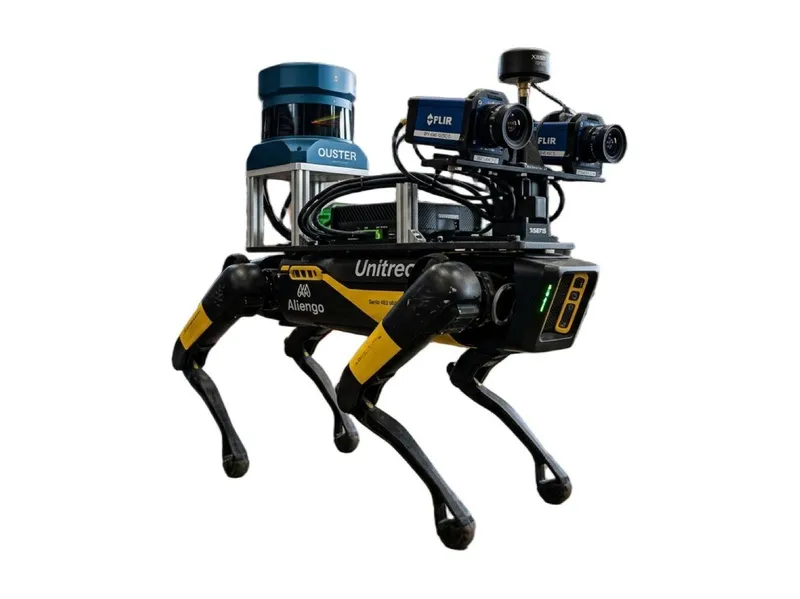
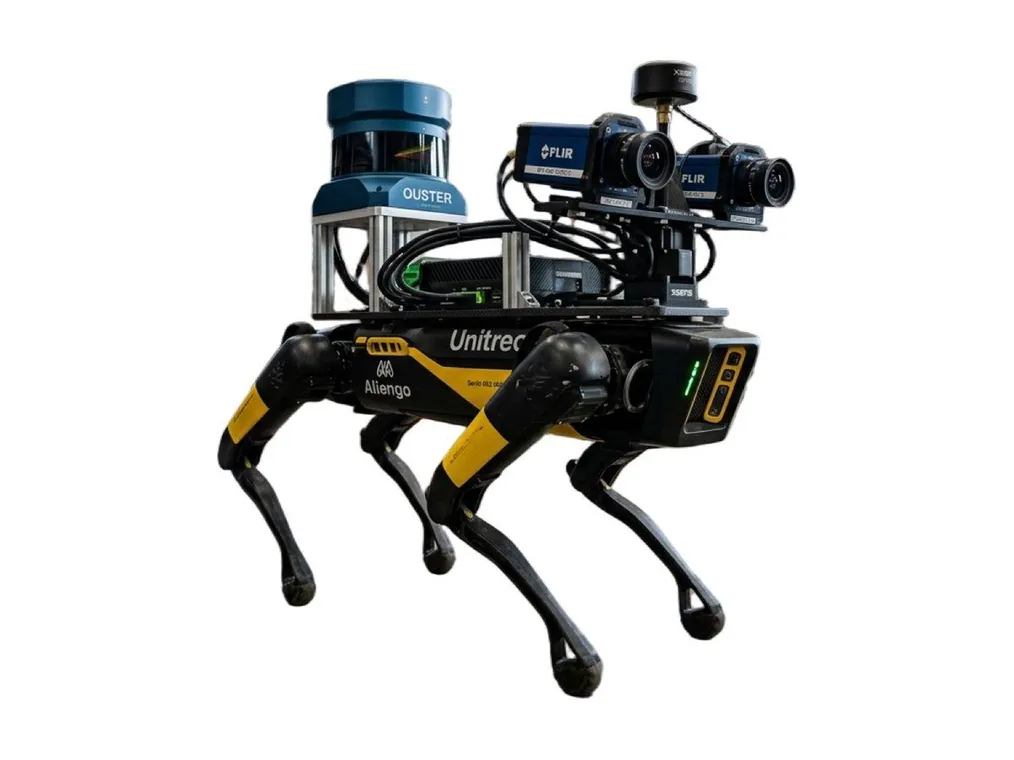
搭载激光雷达与多相机,可在台阶、狭窄通道与室内空间中采集数据,并用于 SLAM 实验。
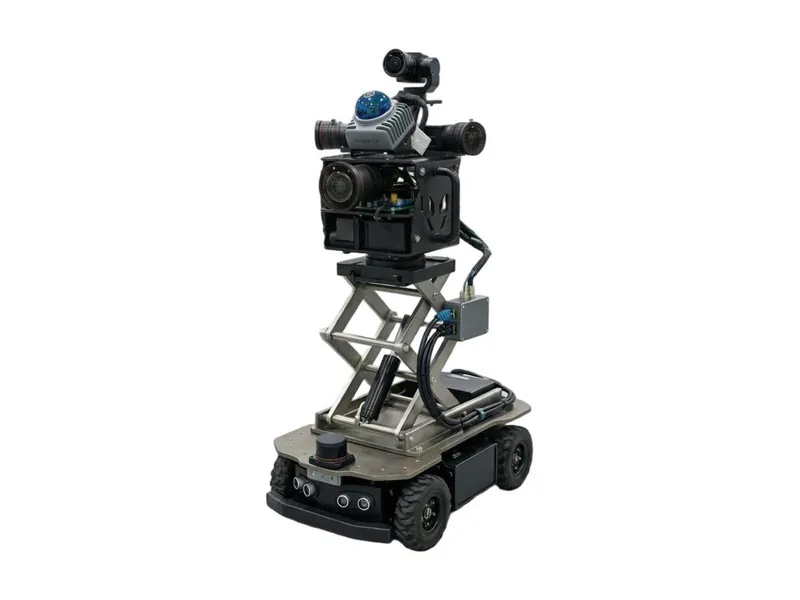
升降云台搭载多传感器,用于建筑立面与室内场景的分层采集。
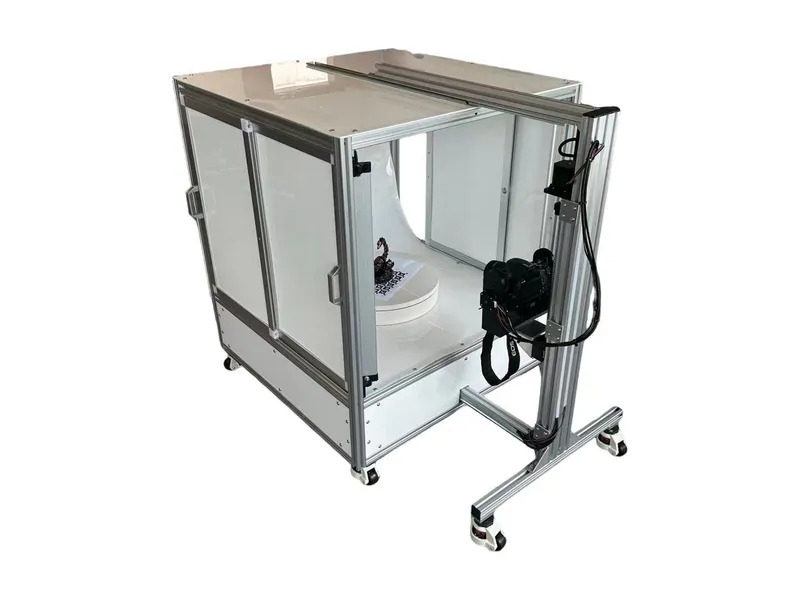
相机、灯光与转台配合,采集单个物体的三维数据。
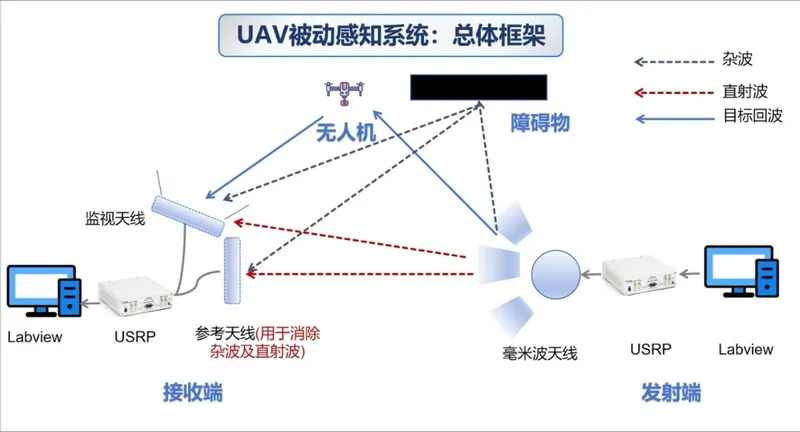
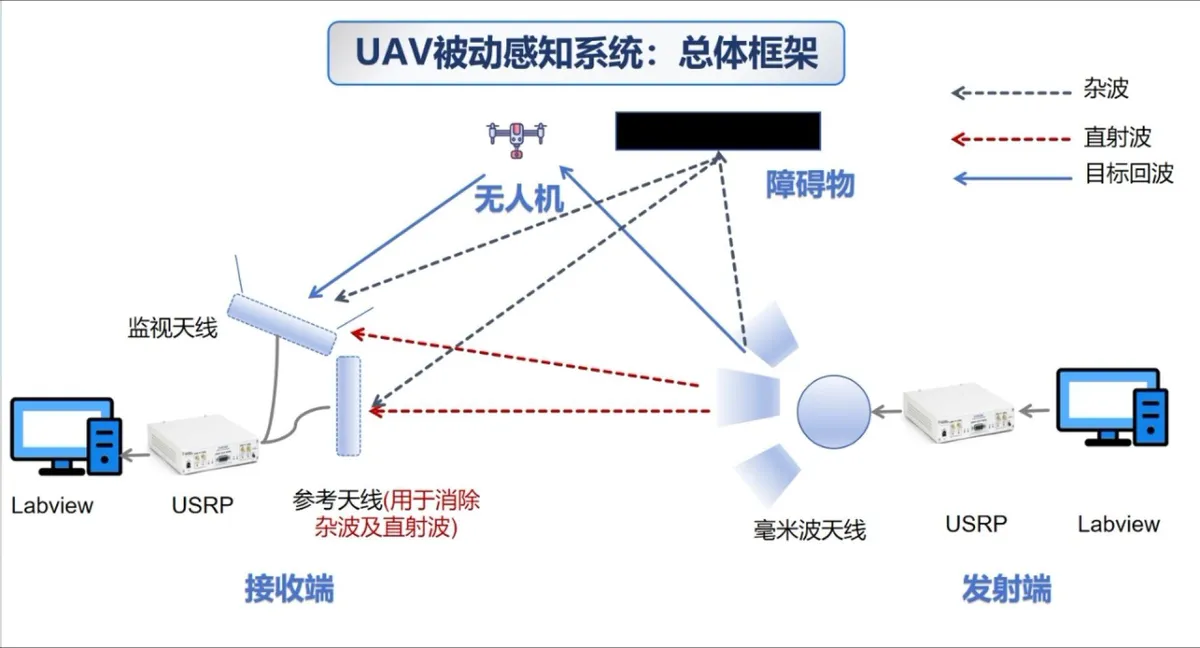
发射端采用毫米波天线与 USRP 软件无线电,接收端采用监视天线、参考天线与 USRP,用于验证无人机被动感知方法。